Singularity free homogeneous half-space triangular dislocation elements
Classical elastic dislocation theory represents a fault as a surface of zero thickness across which displacement jumps. It is enormously useful for kinematic problems. It also has two structural challenges: 1) unphysical coincident stresses and 2) infinitely thin faults. The mollified elastic dislocation theory used here addresses both of those challenges, providing everywhere finite stresses and a representation of finite-width faults. The approach here is appropriate for cases where one wants meaningful element self-stresses or fault zones of extended thickness.
Following Cortez (2001, Cortez et al. 2005, Ferranti and Cortez 2024), the point force is replaced by a smooth blob of width ε,
and the elastostatic equations are then solved exactly for that body force:
The result is singular nowhere and still satisfies the Cauchy equations for static elasticity. A fault therefore has a finite width ε, and stress is defined on the fault, where classical dislocation theory returns a value ordinary integration does not define.
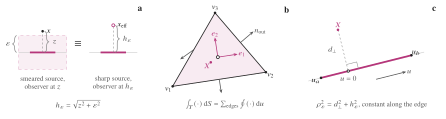
Integrating a mollified source over an arbitrary triangle. a, ε and z merge into a single number — the mollified problem is the classical one at a lifted observer, and hε is the only place ε enters. The frame, the foot and the edges are computed without it. b, the in-plane divergence theorem turns the area integral into three contour integrals, applied as a recursion that trades one step of monomial degree against two powers of R; the solid angle at the lifted observer is its single seed, and the only transcendental beyond a logarithm. c, each edge is parameterised from the foot of its own perpendicular, which makes ρε constant along it and reduces every contour term to a one-dimensional integral in u. Three signed scalars per edge, plus hε, are the whole geometric input.
A half space is imposed by Mindlin’s image construction. That is an image system rather than a single mirrored source: reflecting the geometry is one multiply, but what acts at the reflected point is a monopole at strength (3−4ν), a doublet whose strength scales with the source depth, and a logarithmic term belonging to a vertical line through the image. A single mirror does not satisfy the free-surface condition in elasticity; the whole set does, and nothing less.
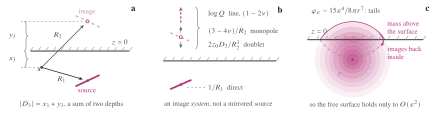
The free surface, by Mindlin images. a, the image is an exact mirror of the geometry, and |D3| is a sum of two absolute depths rather than a separation — so the half-space kernel is not translation-invariant, and depends on where the observer and the source each are, not just on the vector between them. b, three radicals, three geometries: a point at the source, its mirror point, and a vertical line through that mirror, which is what Q is. The line family carries the (1−2ν) prefactor, which is why ν → ½ is the hard case. c, the Cortez blob has algebraic tails, so some of its mass sits above z = 0 and its image lands back inside the body. That is the mechanism behind the O(ε²) below, and the reason an exact free surface by this route is foreclosed rather than pending.
Known limitations
- The free-surface traction condition is only satisfied to O(ε²), not exactly.